
Robot evaluation
Test your robot before it reaches the site
Run your policy in a twin of the building it will work in. Budgets are declared before each run, the simulator grades the outcome, and every attempt is kept as evidence.
What you get
Not a generic scene
Evaluate in a SimReady world built from a scan of the real deployment site.
The simulator decides
A model saying it is done is a stop request. Success is read from the simulator state.
Starts with a scan
Every environment begins as a Scan to BIM delivery: the same separated, measured objects, in Revit and IFC for your BIM team.
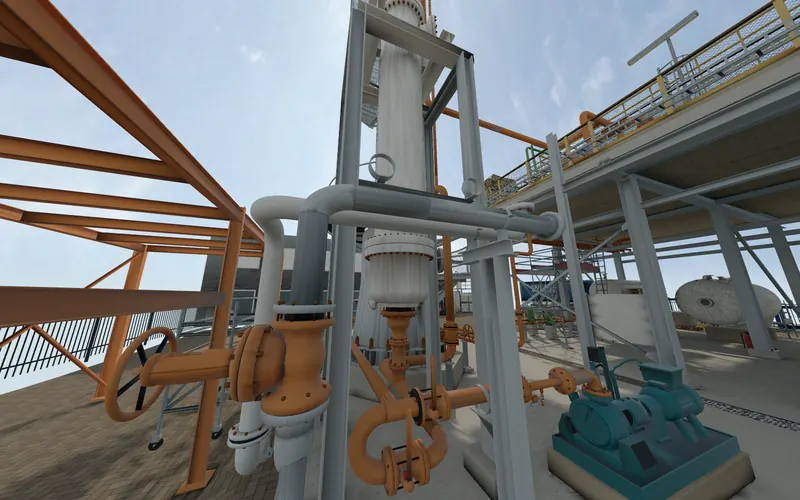 Process plant · Rotterdam
89 separated objects
Pumps, vessels, heat exchangers, stairs, guardrails and pipe networks from a NavVis scan.
Open in 3D →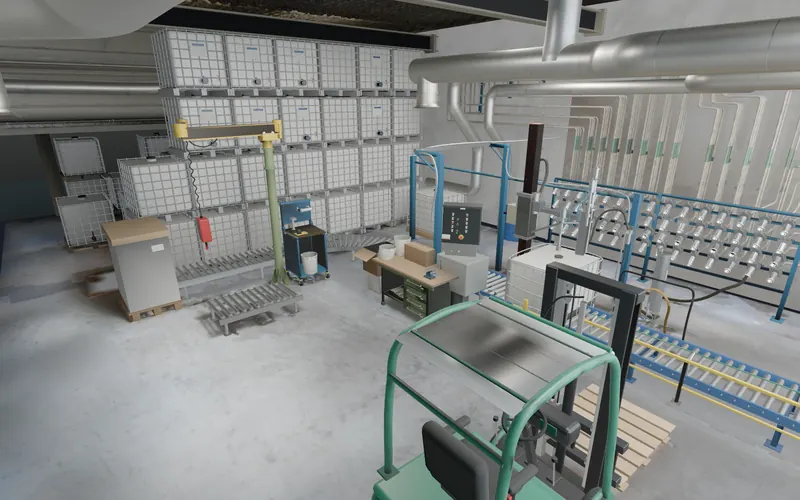 Factory floor
394 objects, Revit model
A NavVis capture of a production bay rebuilt with racking, totes, conveyors and pipework.
Open in 3D →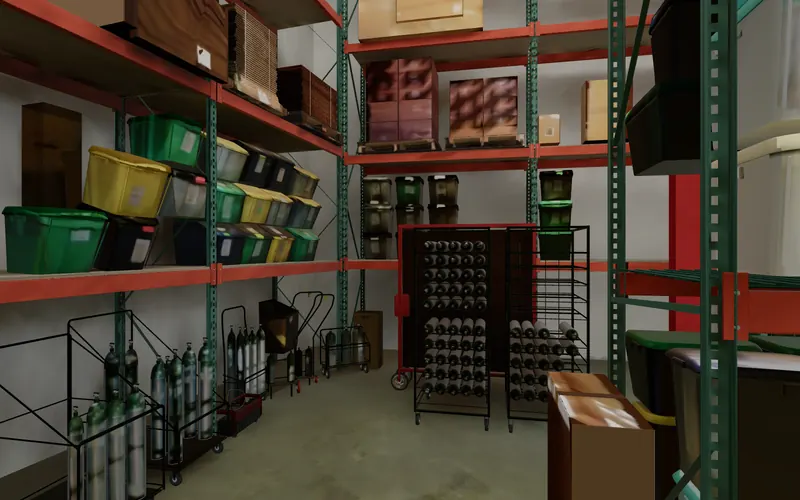 Medical warehouse
1,575 objects, Revit model
A phone capture from Niantic Spatial rebuilt as individually editable assets.
Open in 3D →Bring us your site
Send a scan, or book a call to scope a SimReady world.