
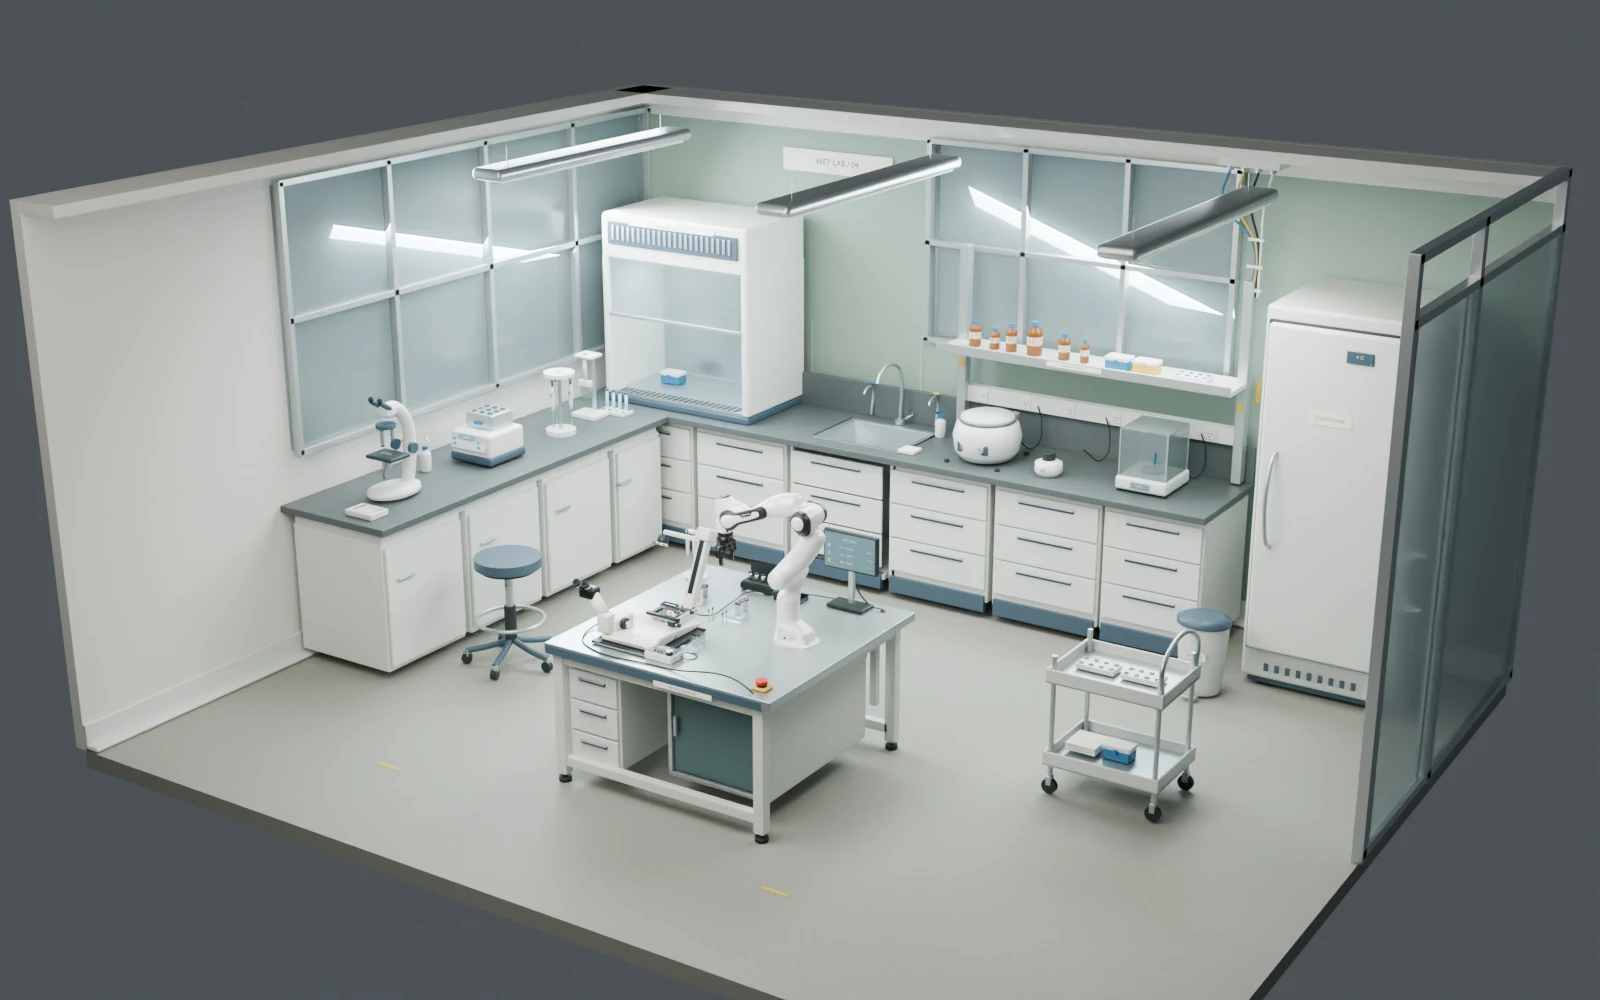
Public environment · Wet lab
One slide out. The right slide precisely in.
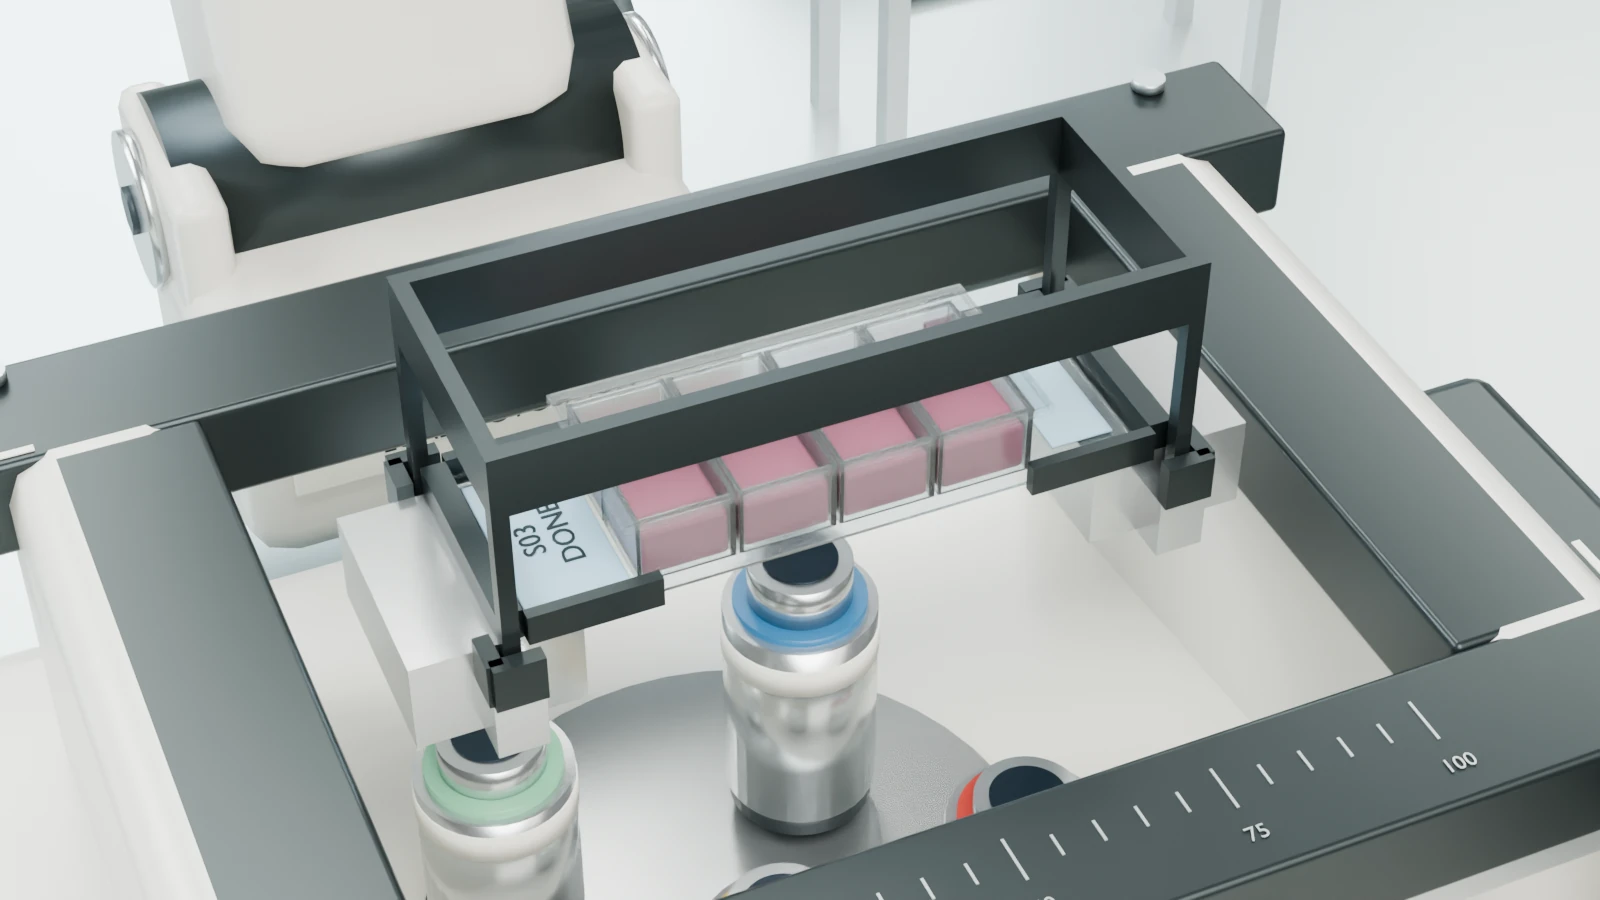
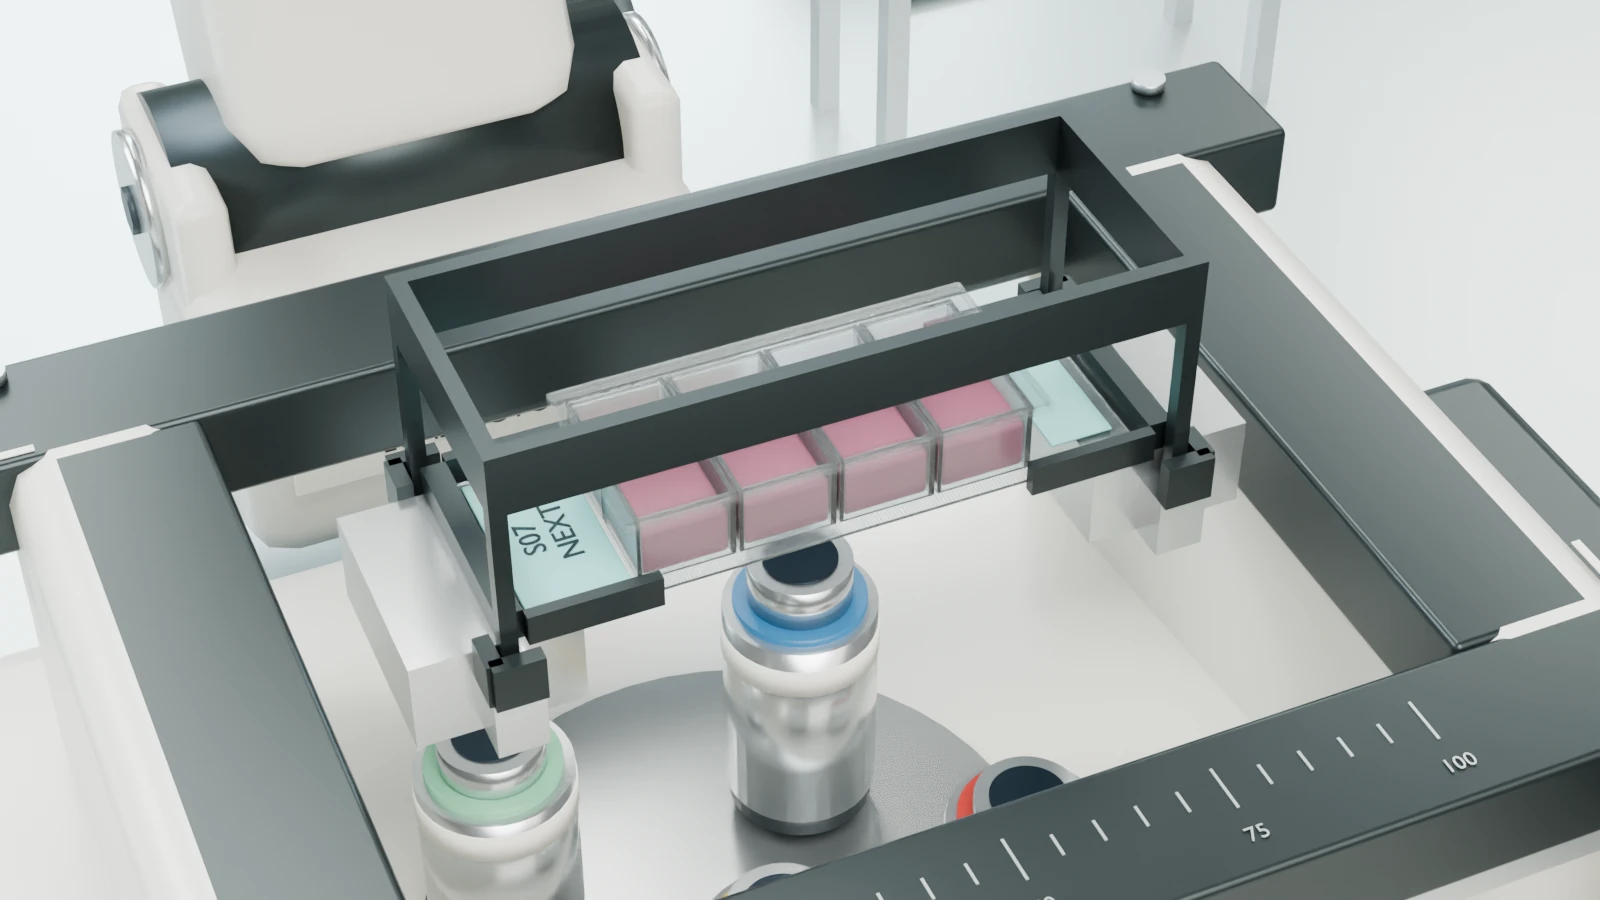
Thin labware. A separate retaining frame. A 90° change of orientation. Just 0.5 mm clearance on each side of the imaging nest.
75.5 × 25.5 mm
Chamber slide
0.5 mm
Clearance per side
4
Movable assemblies
Ideal depth
Plus fixed-fixture calibration
the task
A precise handling task, made testable.
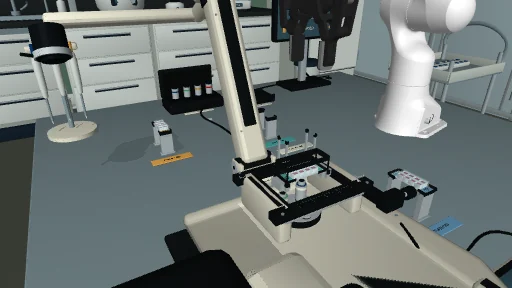
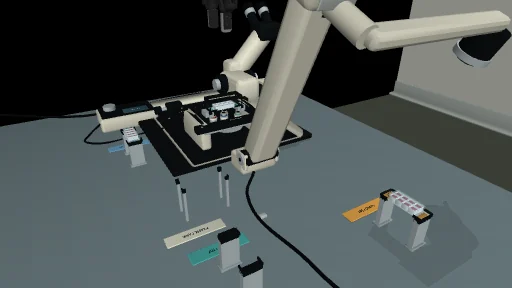
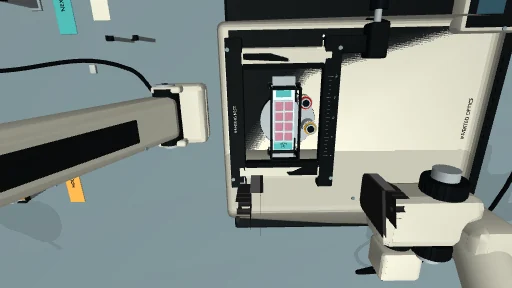
The agent receives three camera views, ideal depth measurements and an explicit map of the fixed fixtures and nominal handling heights. Its task is to exchange S03 for S07, orient the label toward the stage ruler’s zero end, restore the frame and leave S09 HOLD undisturbed.
- 01 Clear the stage
Lift the separate retaining frame to its parking stand.
- 02 Return the finished slide
Move S03 into the return rest.
- 03 Orient and seat S07
Turn the next slide 90° and fit it into the imaging nest.
- 04 Restore the retainer
Replace the frame, release it and inspect the result.
Atom · GPT-6 Astra · RGB + ideal depth
Watch the actual attempt.
Actual recorded simulation, rendered in Blender Cycles. Robot motion plays at 2× simulated speed and inference pauses are omitted.
measured results
Check the outcome.
One accepted nominal run after iteration, checked by an independent post-run review of sequence, alignment, release and final stability.
These measurements describe authored simulation geometry and do not establish reliability across layouts. Liquid behaviour, assay results, magnetic preload and force-limited hardware handling are outside this demonstration.
Independent review · Precision microscopy
| Slide alignment | 0.253 mm · maximum final error along either horizontal axis |
| Slide yaw | 0.105° · relative to the imaging nest |
| HOLD movement | 0.000 mm · largest displacement during the whole trial |
| Simulated time | 59.90 s · five model calls · physics paused during inference |
Inspect
Frames from the record.
make it yours
Start here. Change the conditions.
The nest clearance of 0.5 mm per side is an authored test condition, not a manufacturer tolerance. The run used ideal RGB and depth, supplied fixed-fixture calibration, paused inference and human evaluation. Prior preparation included scripted feasibility probes and incomplete or failed agent attempts. Get an editable copy of the complete wet lab on RobotGym: microscope, sample slides, retaining frame and task setup, opening in Evaluate with the robot and cameras configured.
Creating a copy is free. Simulation previews, policy runs and environment edits use your account’s credits.
Files
Related
Other demos